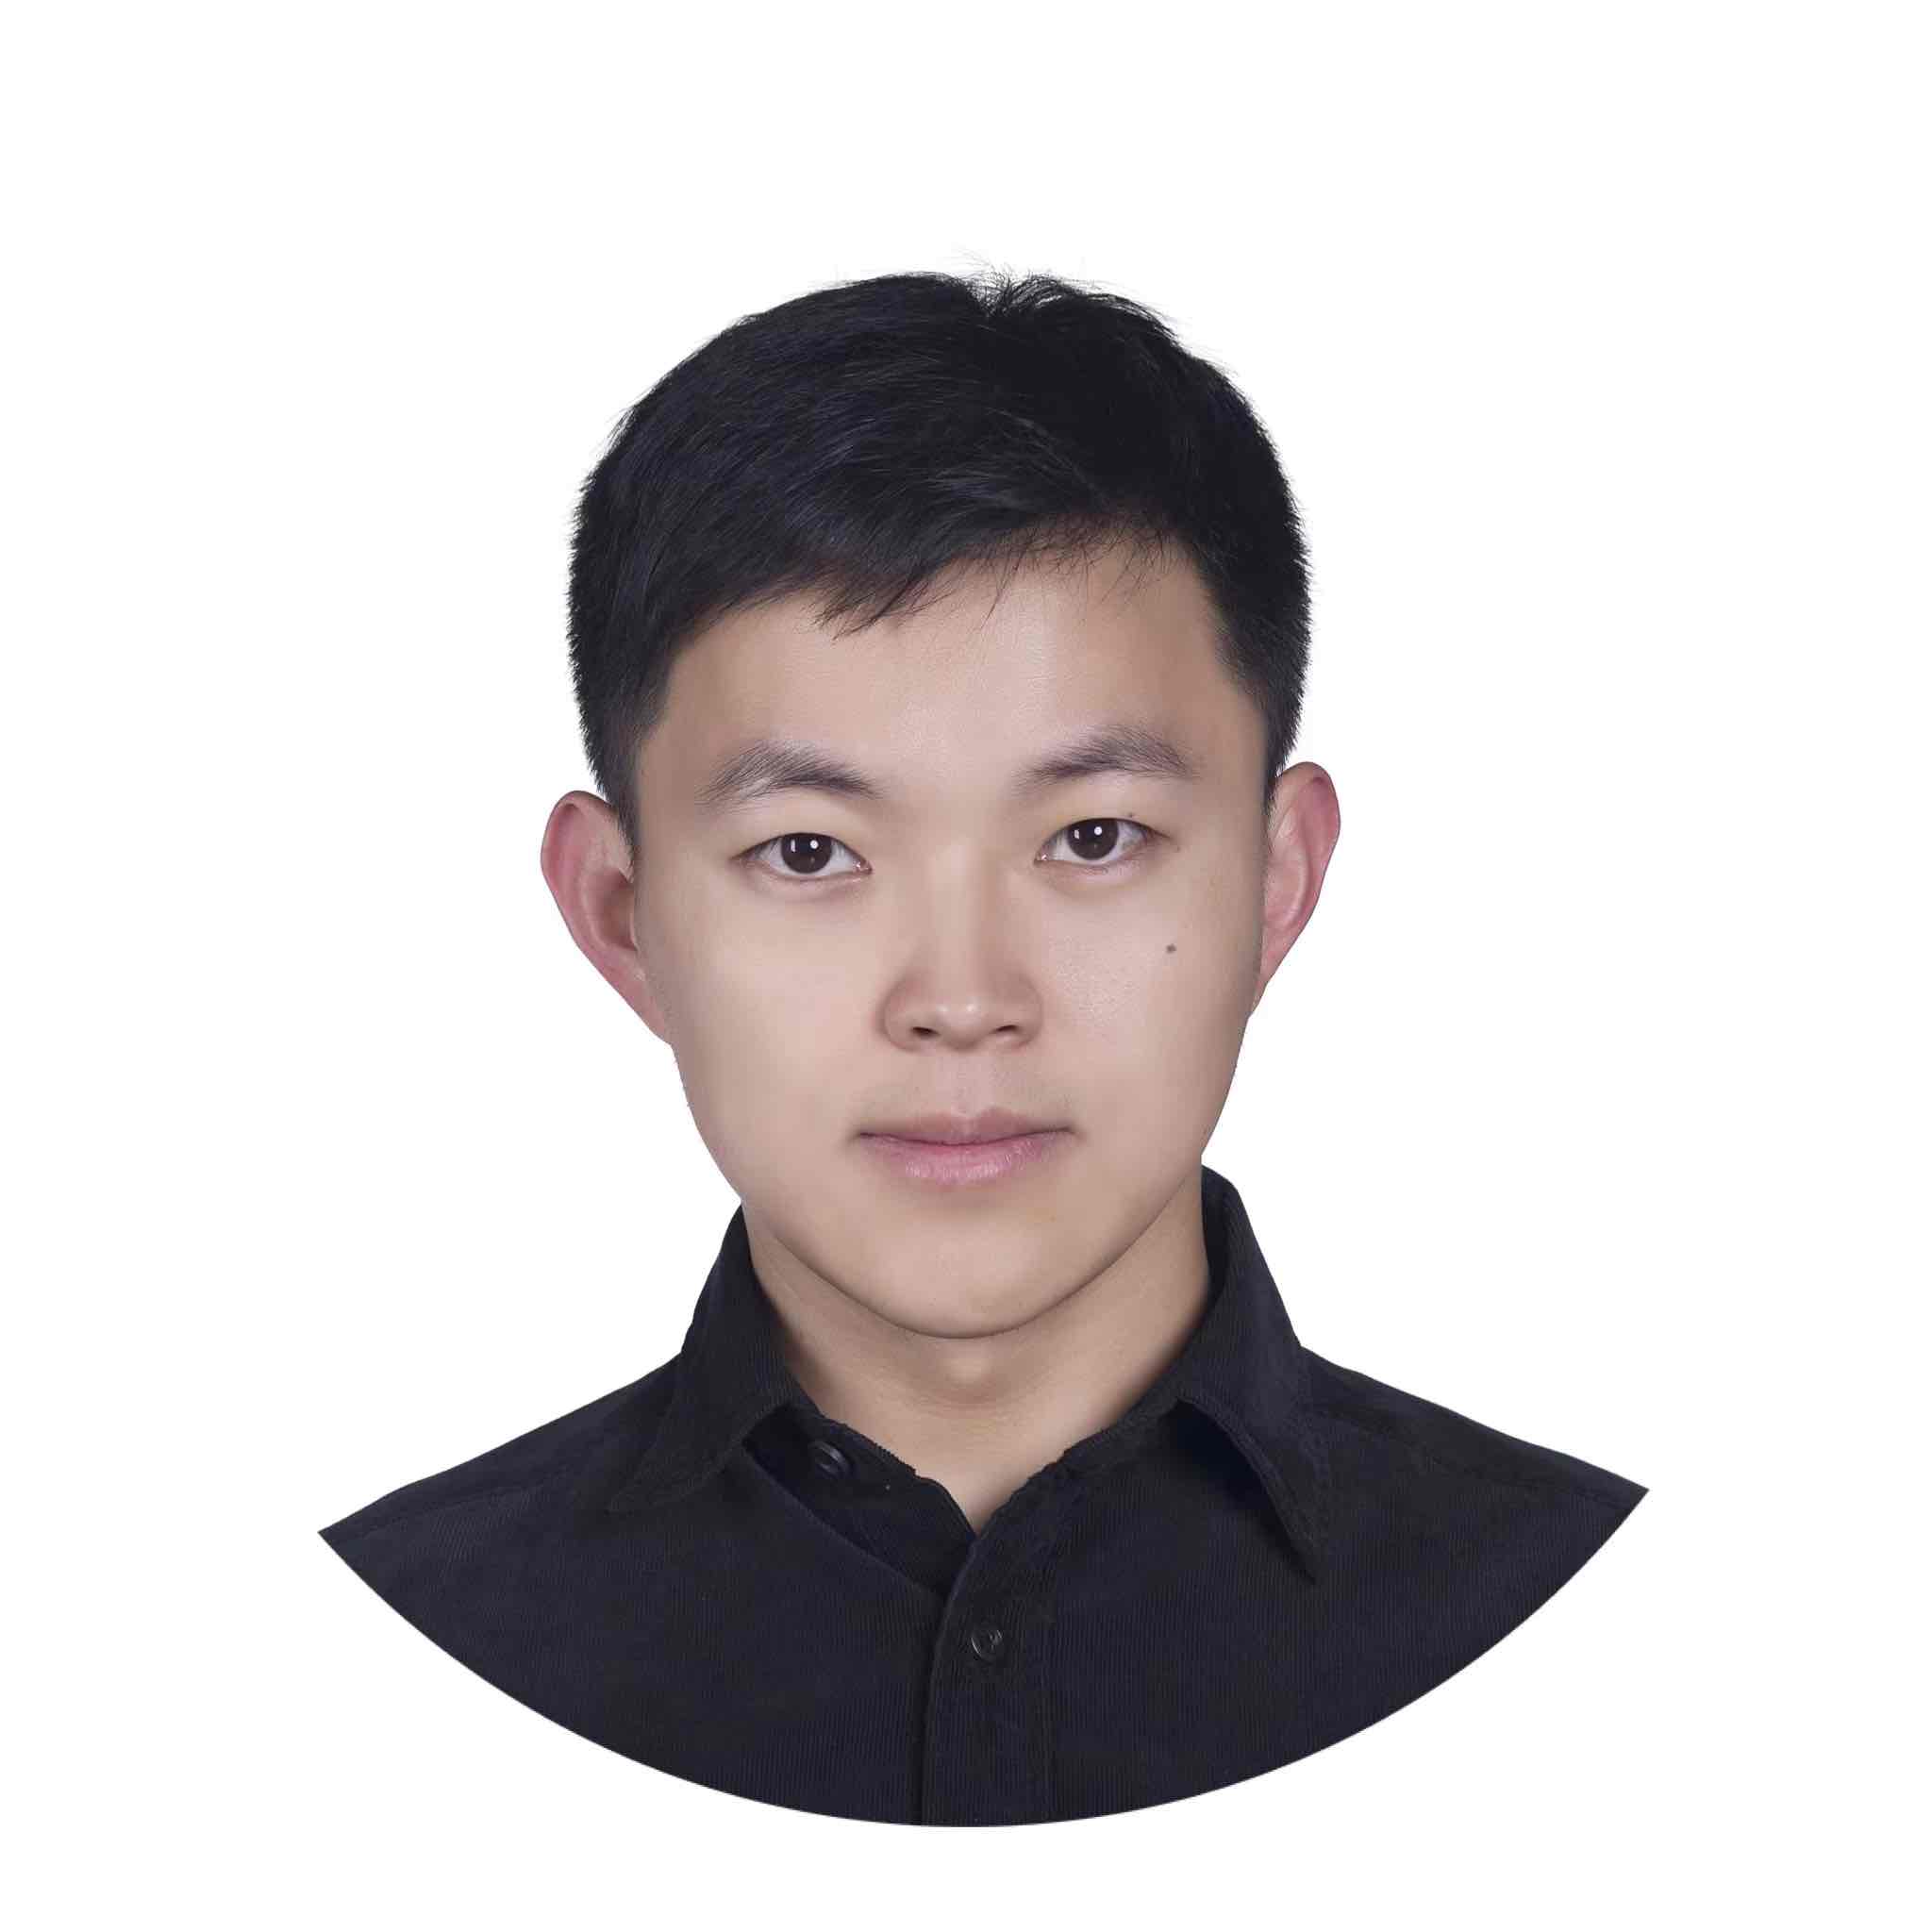
Xianghong Xue
薛向宏
Associate Professor, Deputy Head of Department
School of Automation and Information Engineering
Xi'an University of Technology
My research focuses on cooperative planning and control of UAV swarms and spacecraft formations. My work is supported by the Youth Program (Category B) of the Shaanxi Provincial Natural Science Foundation and the Young Talent Support Program of the Xi'an Association for Science and Technology. I have published more than 30 papers in journals and conferences, over 20 of which are indexed by SCI or EI, filed or been granted more than 10 national invention patents, and contributed to one group standard. I have served as principal investigator on over 10 research projects, including the NSFC Young Scientists Fund, the Shaanxi Key R&D Program, the Aeronautical Science Foundation of China and the China Postdoctoral Science Foundation. I received my Ph.D. from the School of Astronautics, Northwestern Polytechnical University, advised by Prof. Xiaokui Yue.
Students interested in aerospace research are welcome to join our team
Get in touch — xhxue@xaut.edu.cnResearch
Cooperative Control of UAV Swarms
Connectivity preservation, formation control and obstacle avoidance under limited communication range, communication delays, node failures and actuator saturation, together with vision-feedback-based adaptive formation control and cooperative suspended transport in denied environments.
Spacecraft Formation Control
Connectivity preservation, collision avoidance, attitude coordination and control-graph optimization for spacecraft formation flying, along with the optimization of LEO navigation augmentation constellations and the reconfiguration of failed constellations.
Robot Motion Planning
Path planning and motion planning for mobile robots and UAVs in complex environments; lecturer of the undergraduate course Robot Motion Planning.
Projects
All listed projects as principal investigator
-
2026.01 – 2028.12
Ongoing
Connectivity Preservation and Cooperative Control for Intelligent Unmanned Swarm Systems
Shaanxi Provincial Natural Science Foundation, Youth Program (Category B)
-
2025.06 – 2026.12
Ongoing
Cross-Medium Heterogeneous Multi-Source Cooperative Detection and Tracking for Multiple Surface Targets
Shaanxi Key R&D Program, Open-Competition Project
-
2022.01 – 2024.12
Completed
Connectivity Preservation Control for UAV Swarms under Communication Distance Constraints
Young Scientists Fund, National Natural Science Foundation of China
-
2024.07 – 2025.10
Completed
Vision-Feedback-Based Adaptive UAV Formation Control in Denied Environments
Aeronautical Science Foundation of China
-
2023.07 – 2025.06
Completed
Young Talent Support Program
Xi'an Association for Science and Technology
-
2023.01 – 2024.12
Completed
Development of a Helicopter Rotor Shaft Center Trajectory Measurement System
Shaanxi Key R&D Program, General Project
-
2022.01 – 2023.12
Completed
Connectivity Preservation Control for Ad-Hoc Network UAV Swarms
China Postdoctoral Science Foundation, General Program
-
2021.01 – 2022.12
Completed
Connectivity Preservation Control Methods for Ad-Hoc Network UAV Swarms
Natural Science Program, Shaanxi Provincial Department of Education
Publications
Full list on Google ScholarJournal papers as first or corresponding author; * denotes the corresponding author
2026
-
Connectivity preservation, collision avoidance, and control graph optimization for spacecraft formation flying with directed graphs
T. Song, X. Xue*, Y. Ren, Y. Zhang, L. Mu
Aerospace Science and Technology, 179: 113374, 2026 DOI
-
Connectivity preservation control for multiple unmanned aerial vehicles under communication delays
B. Yuan, X. Xue*, Y. Yi, Y. Ren, Y. Zhang
Asian Journal of Control, 2026 DOI
-
Cooperative suspension transport method for multiple UAVs under unknown wind disturbances
Z. Shen, X. Tian, H. Xiong, B. Yuan, X. Xue*
Aerospace Control, 44(4): 64–72, 2026 (in Chinese) DOI
2025
-
Connectivity preservation and obstacle avoidance control for multiple quadrotor UAVs with limited communication distance
X. Xue, B. Yuan, Y. Yi, L. Mu, Y. Zhang*
Drones, 9(2): 136, 2025 PDF
-
A lightweight forest fire detection method based on UAV dual-modal images
L. Mu, Y. Yang, Y. Zhang, X. Xue*, N. Feng
IEEE Geoscience and Remote Sensing Letters, 22: 7001805, 2025 PDF
-
A non-dominated sorting genetic algorithm for the optimization of LEO navigation augmentation constellations
X. Xue*, T. Song, Y. Zhang, L. Mu
Journal of Astronautics, 46(6): 1214–1227, 2025 (in Chinese) PDF
2024
-
Connectivity preservation control for multiple unmanned aerial vehicles in the presence of bounded actuation
X. Xue, B. Yuan, Y. Yi*, Y. Zhang, X. Yue, L. Mu
ISA Transactions, 152: 28–37, 2024 PDF
-
Leader-following connectivity preservation and collision avoidance control for multiple spacecraft with bounded actuation
X. Xue*, X. Wang, N. Han*
Aerospace, 11(8): 612, 2024 PDF
-
Robust topological insulating property in C2X-functionalized III–V monolayers
X. Xue, Z. Lin, R. Gao, B. Yang, H. Wang, M. Han, N. Han
Nanotechnology, 35(50): 505203, 2024
2021
-
Connectivity preservation and collision avoidance control for spacecraft formation flying in the presence of multiple obstacles
X. Xue*, X. Yue*, J. Yuan
Advances in Space Research, 67(11): 3504–3514, 2021 PDF
2020
-
Connectivity preservation and collision avoidance for leader-follower spacecraft formation flying
X. Xue, X. Yue*, J. Yuan
Journal of Astronautics, 41(7): 959–969, 2020 (in Chinese) PDF
2019
-
Adaptive control for attitude coordination of leader-following rigid spacecraft systems with inertia parameter uncertainties
X. Yue, X. Xue*, H. Wen, J. Yuan
Chinese Journal of Aeronautics, 32(3): 688–700, 2019 PDF
Invention Patents
Granted
-
A connectivity preservation control algorithm and system for UAV swarms
ZL202511588820.1 2026.02.24
-
Trajectory planning for unmanned swarms based on the Tangent Bug algorithm and real-time virtual tubes
ZL202610052656.0 2026.04.10
-
A cooperative control method for UAV swarms under three-dimensional field-of-view constraints
ZL202611003019.0 2026.07.07
-
A graph-rigidity-based cooperative suspended transport control method for multiple UAVs
ZL202611090736.1 2026.09.18
Filed
-
A cooperative tracking task allocation method for multiple UAVs against dynamic multi-targets
CN202610750170.4 2026.05.28
-
A connectivity preservation control method for multiple UAVs with node failures
CN202511493108.3 2025.10.20
-
A spacecraft formation flying control method using the null-space-based behavioral approach
CN202510839386.3 2025.06.23
-
A reconfiguration method for failed satellite constellations based on an unlocking genetic algorithm
CN202510831108.3 2025.06.20
-
An optimization method for LEO navigation augmentation hybrid constellations using a non-dominated sorting genetic algorithm
CN202411199074.2 2024.12.06
-
A connectivity preservation control method for multiple UAVs considering input saturation
CN202410377783.9 2024.07.26
Awards
-
2026
Second Prize, Science and Technology Award of the Shaanxi Society of Aeronautics
-
2026
Best Paper Award, IRCE 2026
-
2024
Outstanding Reviewer, Journal of Astronautics
-
2023
National First Prize, China Robotics and Artificial Intelligence Competition (advisor)
-
2023
Outstanding Advisor, China Robotics and Artificial Intelligence Competition
-
2023
Outstanding Advisor, Northwest Division, China Graduate Electronics Design Contest
Education
-
2015.04 – 2020.10
Ph.D. in Flight Vehicle Design
School of Astronautics, Northwestern Polytechnical University
-
2012.09 – 2015.03
M.Eng. in Software Engineering
Northwestern Polytechnical University
-
2008.09 – 2012.07
B.S. in Information and Computing Science
Xi'an University of Technology
Teaching
-
Undergraduate lecture courses
Robot Motion Planning, Discrete Mathematics
-
Undergraduate practical course
Comprehensive Course Design of Robot Planning and Control
-
Student supervision
Supervised students who won the National First Prize in the Robot Task Challenge (Micro UAV) of the China Robotics and Artificial Intelligence Competition, and the First Prize of the Northwest Division of the China Graduate Electronics Design Contest
Academic Service
-
Society appointments
Member, Technical Committee on Navigation, Guidance and Control, Chinese Association of Automation
Young Member, Navigation, Guidance and Control Branch, Chinese Society of Aeronautics and Astronautics
Member, Education and Outreach Committee, Shaanxi Association of Automation
Council Member, Xi'an Association of Automation -
Editorial board
Young Editorial Board Member, Journal of Naval Aviation University
-
Journal reviewer
IEEE TAES, IEEE TFS, IEEE RA-L, Aerospace Science and Technology, ISA Transactions, Engineering Applications of Artificial Intelligence, Applied Soft Computing, Computers and Electronics in Agriculture, Robotics and Autonomous Systems, Systems & Control Letters, Journal of Astronautics, and others